Category: Talk
-
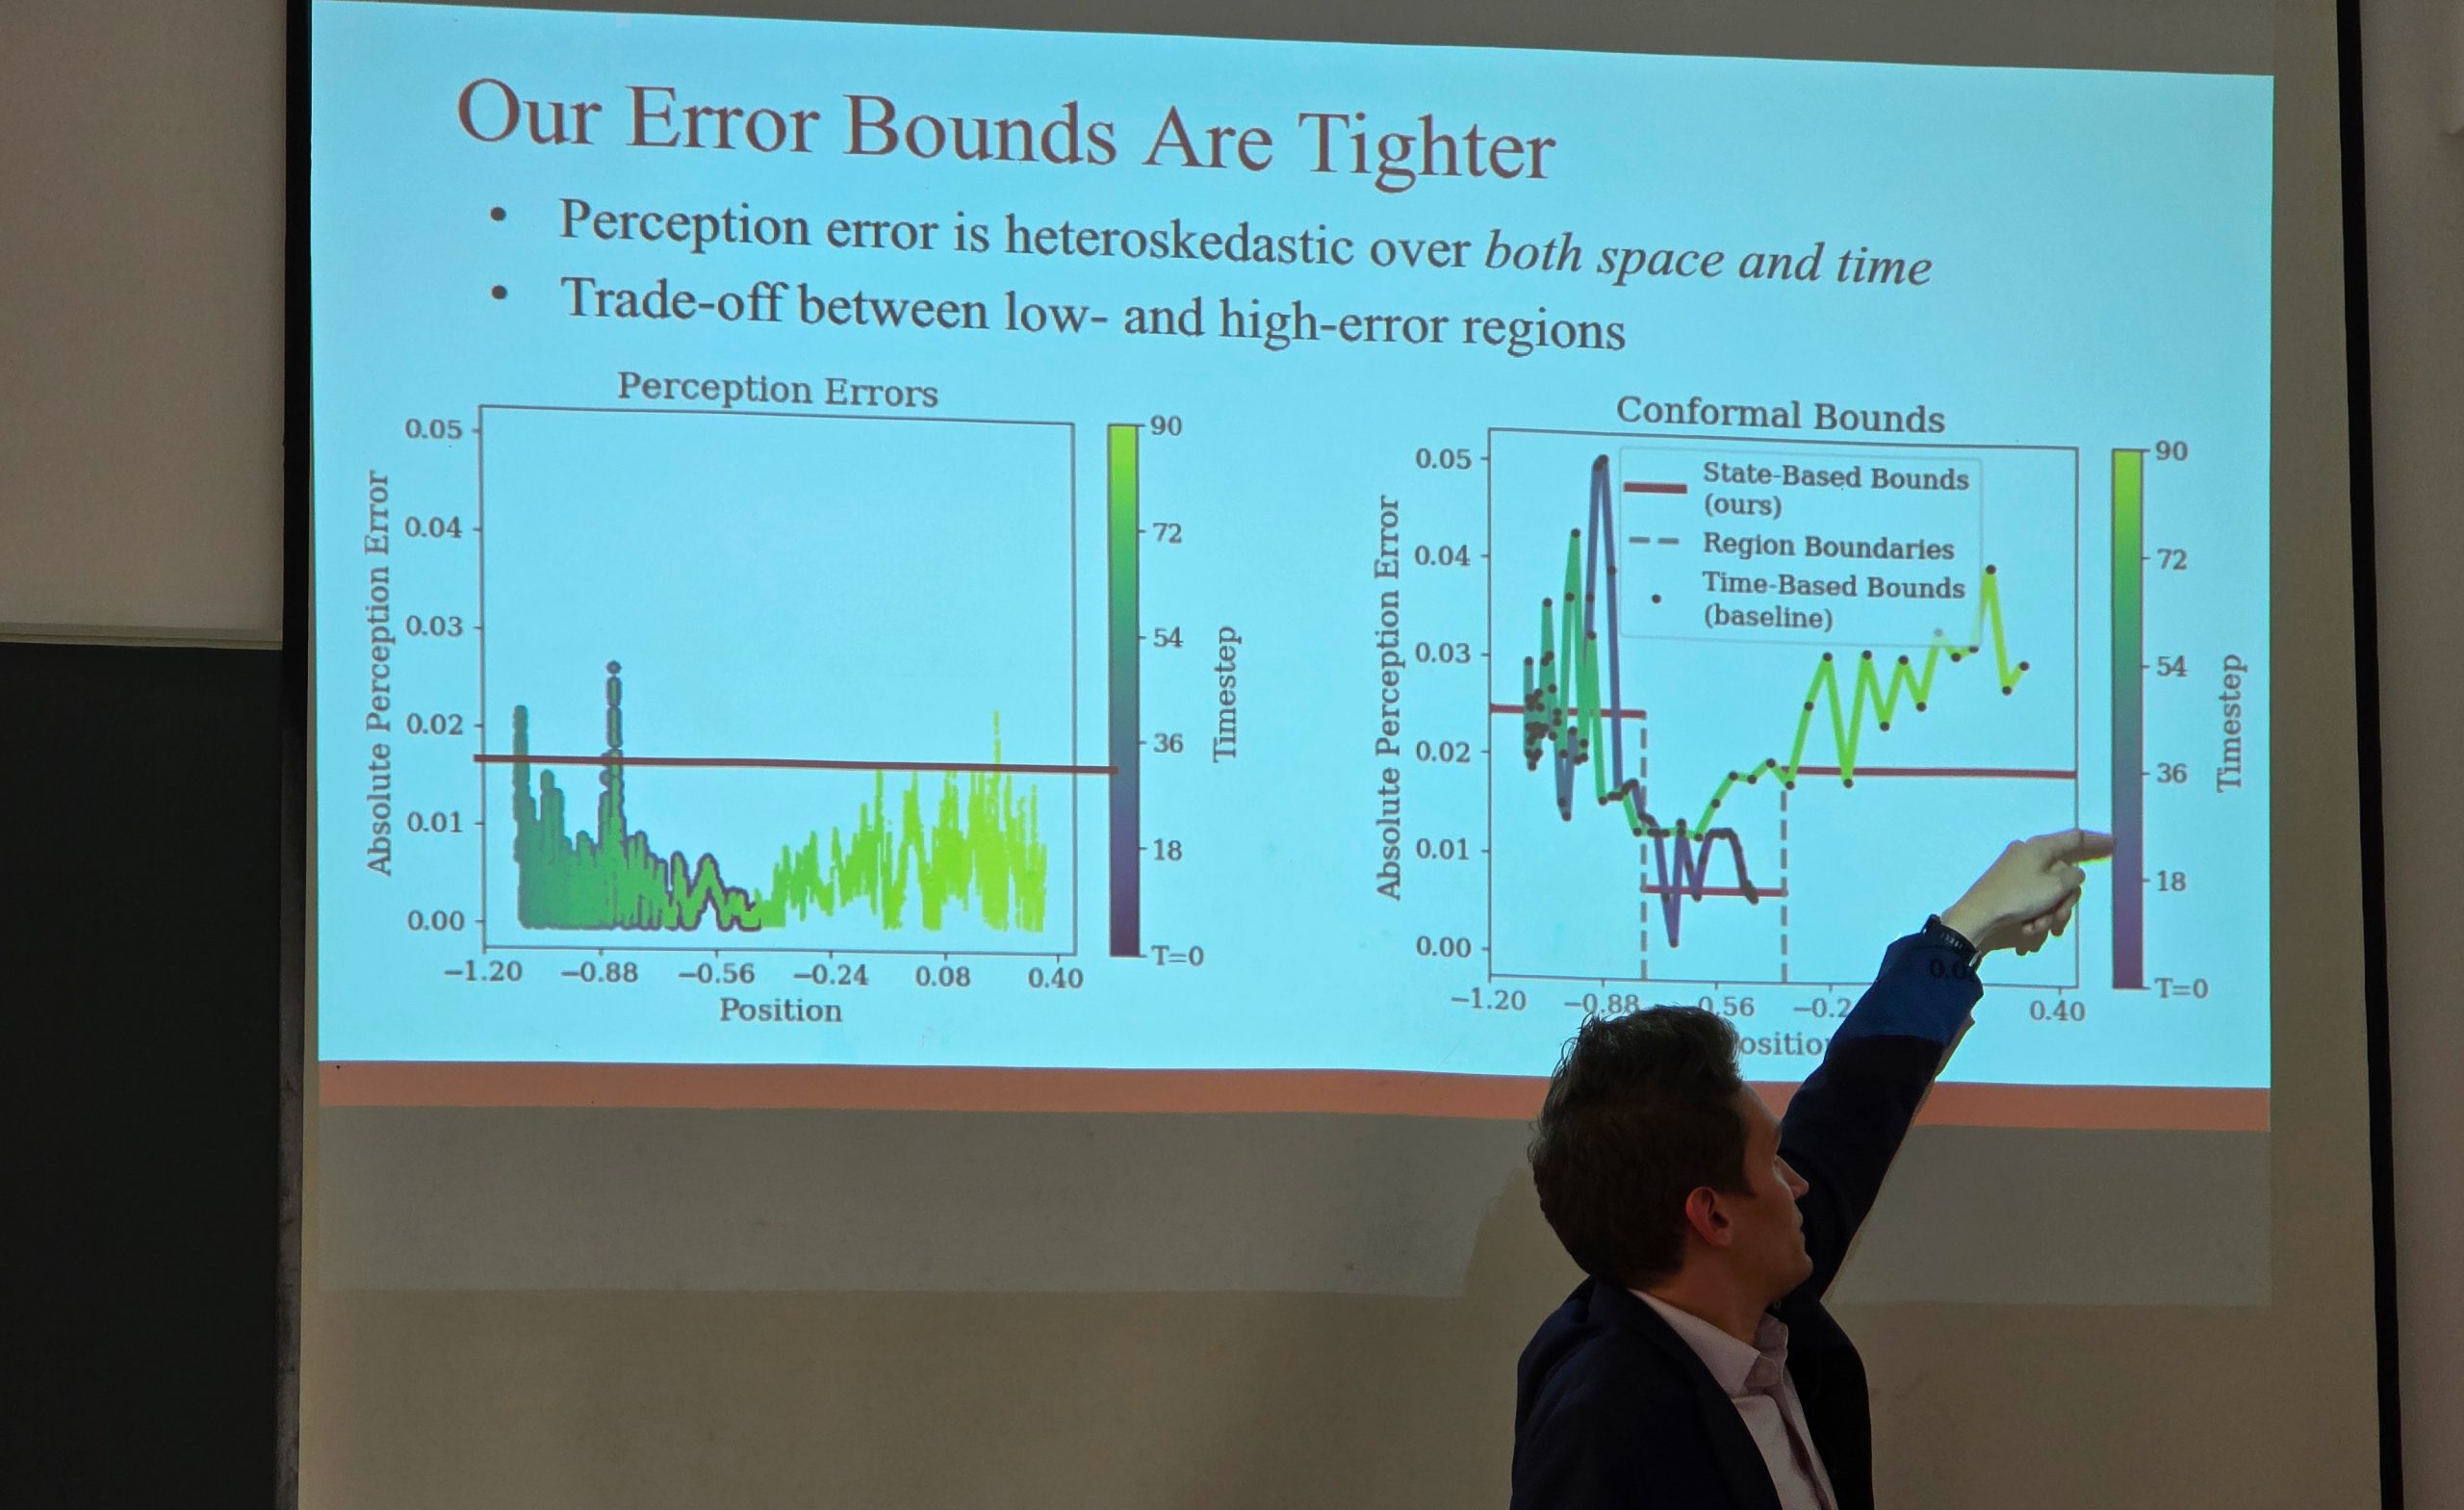
Ivan talks about conformal reachability at CAV
—
Ivan went all the way to Croatia to tell people how to put conformal prediction in a closed loop at the International Conference on Computer-Aided Verification (CAV). Doing so would let you verify autonomous systems with neural networks of any size (yes, even a VLA model like RT-2!). The decisive question is, to apply conformal prediction at…
-

Ivan presents principles of world modeling at NeuS 2025
—
Ivan revisited his old grazing grounds in Philly to present 4 principles for making world models more physically grounded. There was an intense discussion of whether purely symbolic simulators should count as generative world models. Citation: In the meantime, the RPI collaborators Thomas and Rado presented a joint work on state-based conformal prediction. Citation:
-

Jordan & Ivan present world models at ICRA 2025
—
To the audience’s excitement, Jordan and Ivan presented the lab’s work on principles of physically interpretable work models in two capacities: Citation:
-

Jordan and Ivan present at CPS-IoT Week 2025
—
Several events transpired at the CPS-IoT Week in Irvine, CA: Jordan presented his poster (pictured) on probabilistic verification & validation at HSCC. Ivan presented his collaborative work on imprecise neural networks at HSCC. Ivan chaired the ICCPS poster/demo session and a couple of paper sessions, and also judged posters in the PhD forum.
-

Carson & Lorant present at the UF Spring Symposium
Carson Sobolewski and Lorant Domokos presented their posters at the UF Spring Undergraduate Research Symposium 2025 as part of their scholarship programs: Generalizable Image Repair for Robust Visual Autonomous Racing Autonomous Drift Detection and Online Road Friction Estimation Allegedly, Chris Oeltjen was also in attendance.
-

MANY posters, demos, awards at NELMS IoT conference
—
Congratulations to many students from TEA lab presenting their work and getting recognition!
-

Sam, Yuang, Zhenjiang present posters at UF AI Days 2024
—
On October 29, 2024, the three students presented posters about the following papers: Zhenjiang Mao, Dong-You Jhong, Ao Wang, Ivan Ruchkin. Language-Enhanced Latent Representations for Out-of-Distribution Detection in Autonomous Driving [Arxiv] [Slides]. Robot Trust for Symbiotic Societies (RTSS) Workshop (co-located with ICRA 2024), Yokohama, Japan, 2024. Zhenjiang Mao, Siqi Dai, Yuang Geng, Ivan Ruchkin. Zero-shot Safety Prediction…
-
Ivan presents calibrated visual safety prediction at TACPS workshop at ESWEEK
—
Ivan gave an invited talk “How Safe Will I Be Given What I See? Calibrated Visual Safety Chance Prediction with (Foundation) World Models”. The discussion was very active and generated sufficient questions for the rest of Zhenjiang’s PhD. Relevant links: Talk page Workshop page Conference page Slides Talk abstract: In safety-critical autonomous systems, safety prediction…
-

Yuang presents high-dimensional reachability at FM 2024
—
Yuang Geng presented his work on reachability for vision-based neural-network controllers at the 26th International Symposium on Formal Methods (FM). Reportedly, the attendees are curious about the mapping between states and images. Citation and further materials:
-

Zhenjiang presents calibrated safety predictors at L4DC 2024
—
Zhenjiang Mao presented his work on learning-enabled safety prediction (poster, paper) at the 6th Annual Conference on Learning for Decision and Control (L4DC 2024) in Oxford, UK. Reportedly, the attendees like math more than he does. Citation: Zhenjiang Mao, Carson Sobolewski, Ivan Ruchkin. How Safe Am I Given What I See? Calibrated Prediction of Safety…