Category: Conference
-
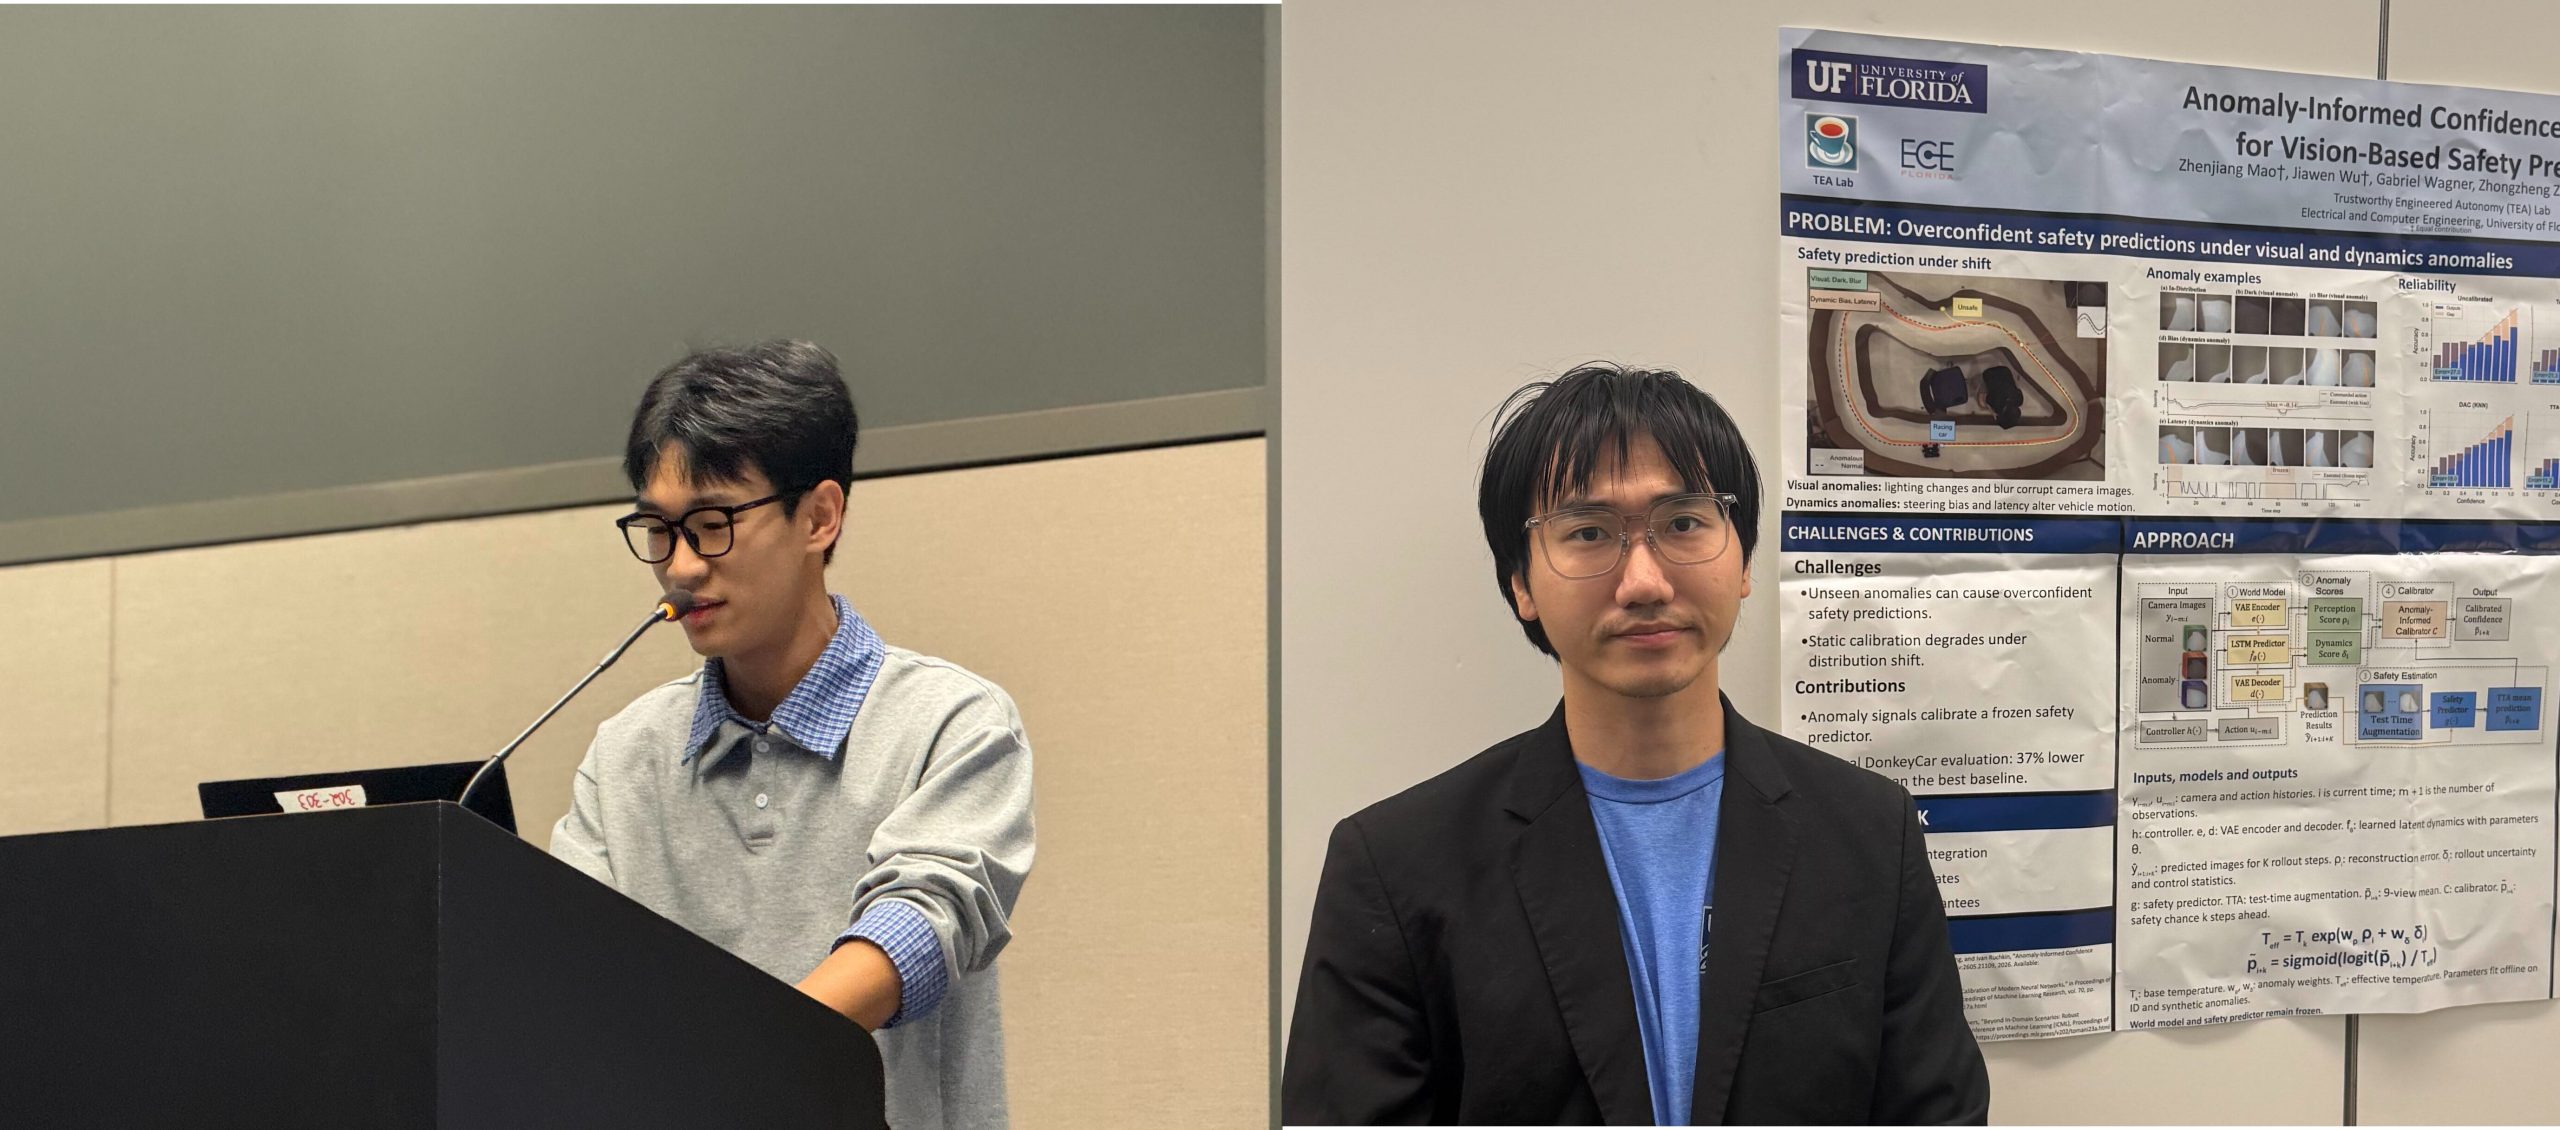
Yuang and Zhenjiang present anomaly research @ IROS
—
Yuang Geng and Zhenjiang Mao went to the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) in Pittsburgh, PA, to present our lab’s work on mitigating anomalies in imitation learning and trajectory prediction. They went to represent UF as part of a bigger Gator robotics crowd. Presented papers:
-
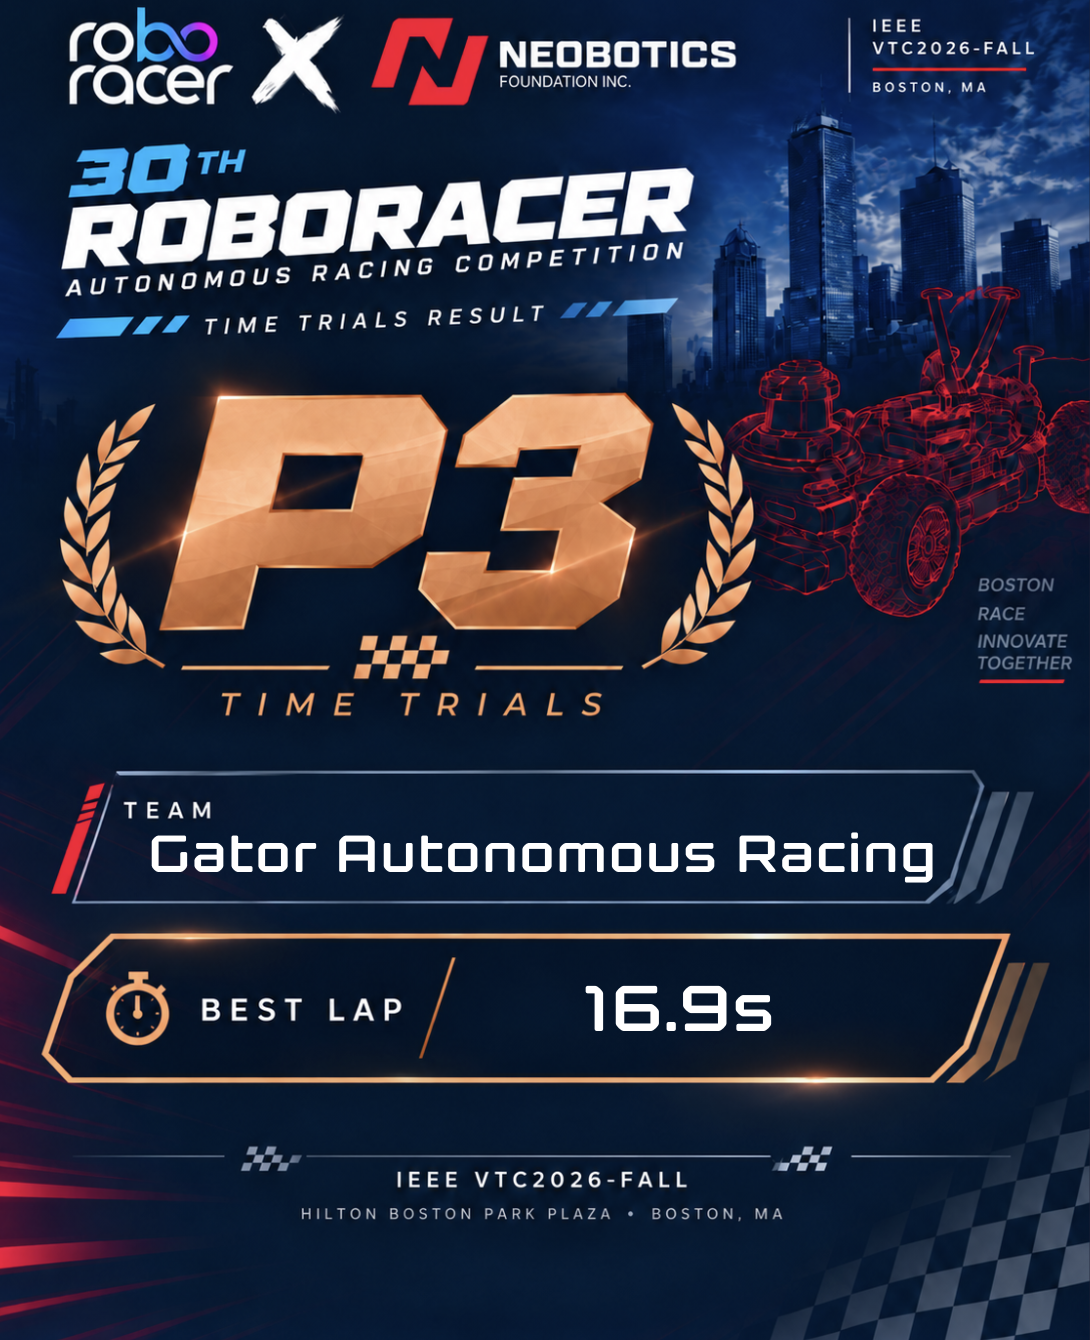
GAR wins 3rd place at vehicle conference in Boston
—
A team of our friends from the Gator Autonomous Racing (GAR) club went to Boston for the Vehicular Technology Conference (VTC) and took third place! That was the first in-person competition for the club. Congratulations, and wishing GAR many more such performances!
-

Zhenjiang and Ani present temporal confidence at ACL’26
—
Ani (who also volunteered) and Zhenjiang traveled to the Association for Computational Linguistics (ACL) conference in San Diego to present our work on using temporal signatures in language model logics to calibrate their correctness confidence. It was an exciting contribution and an exciting trip!
-
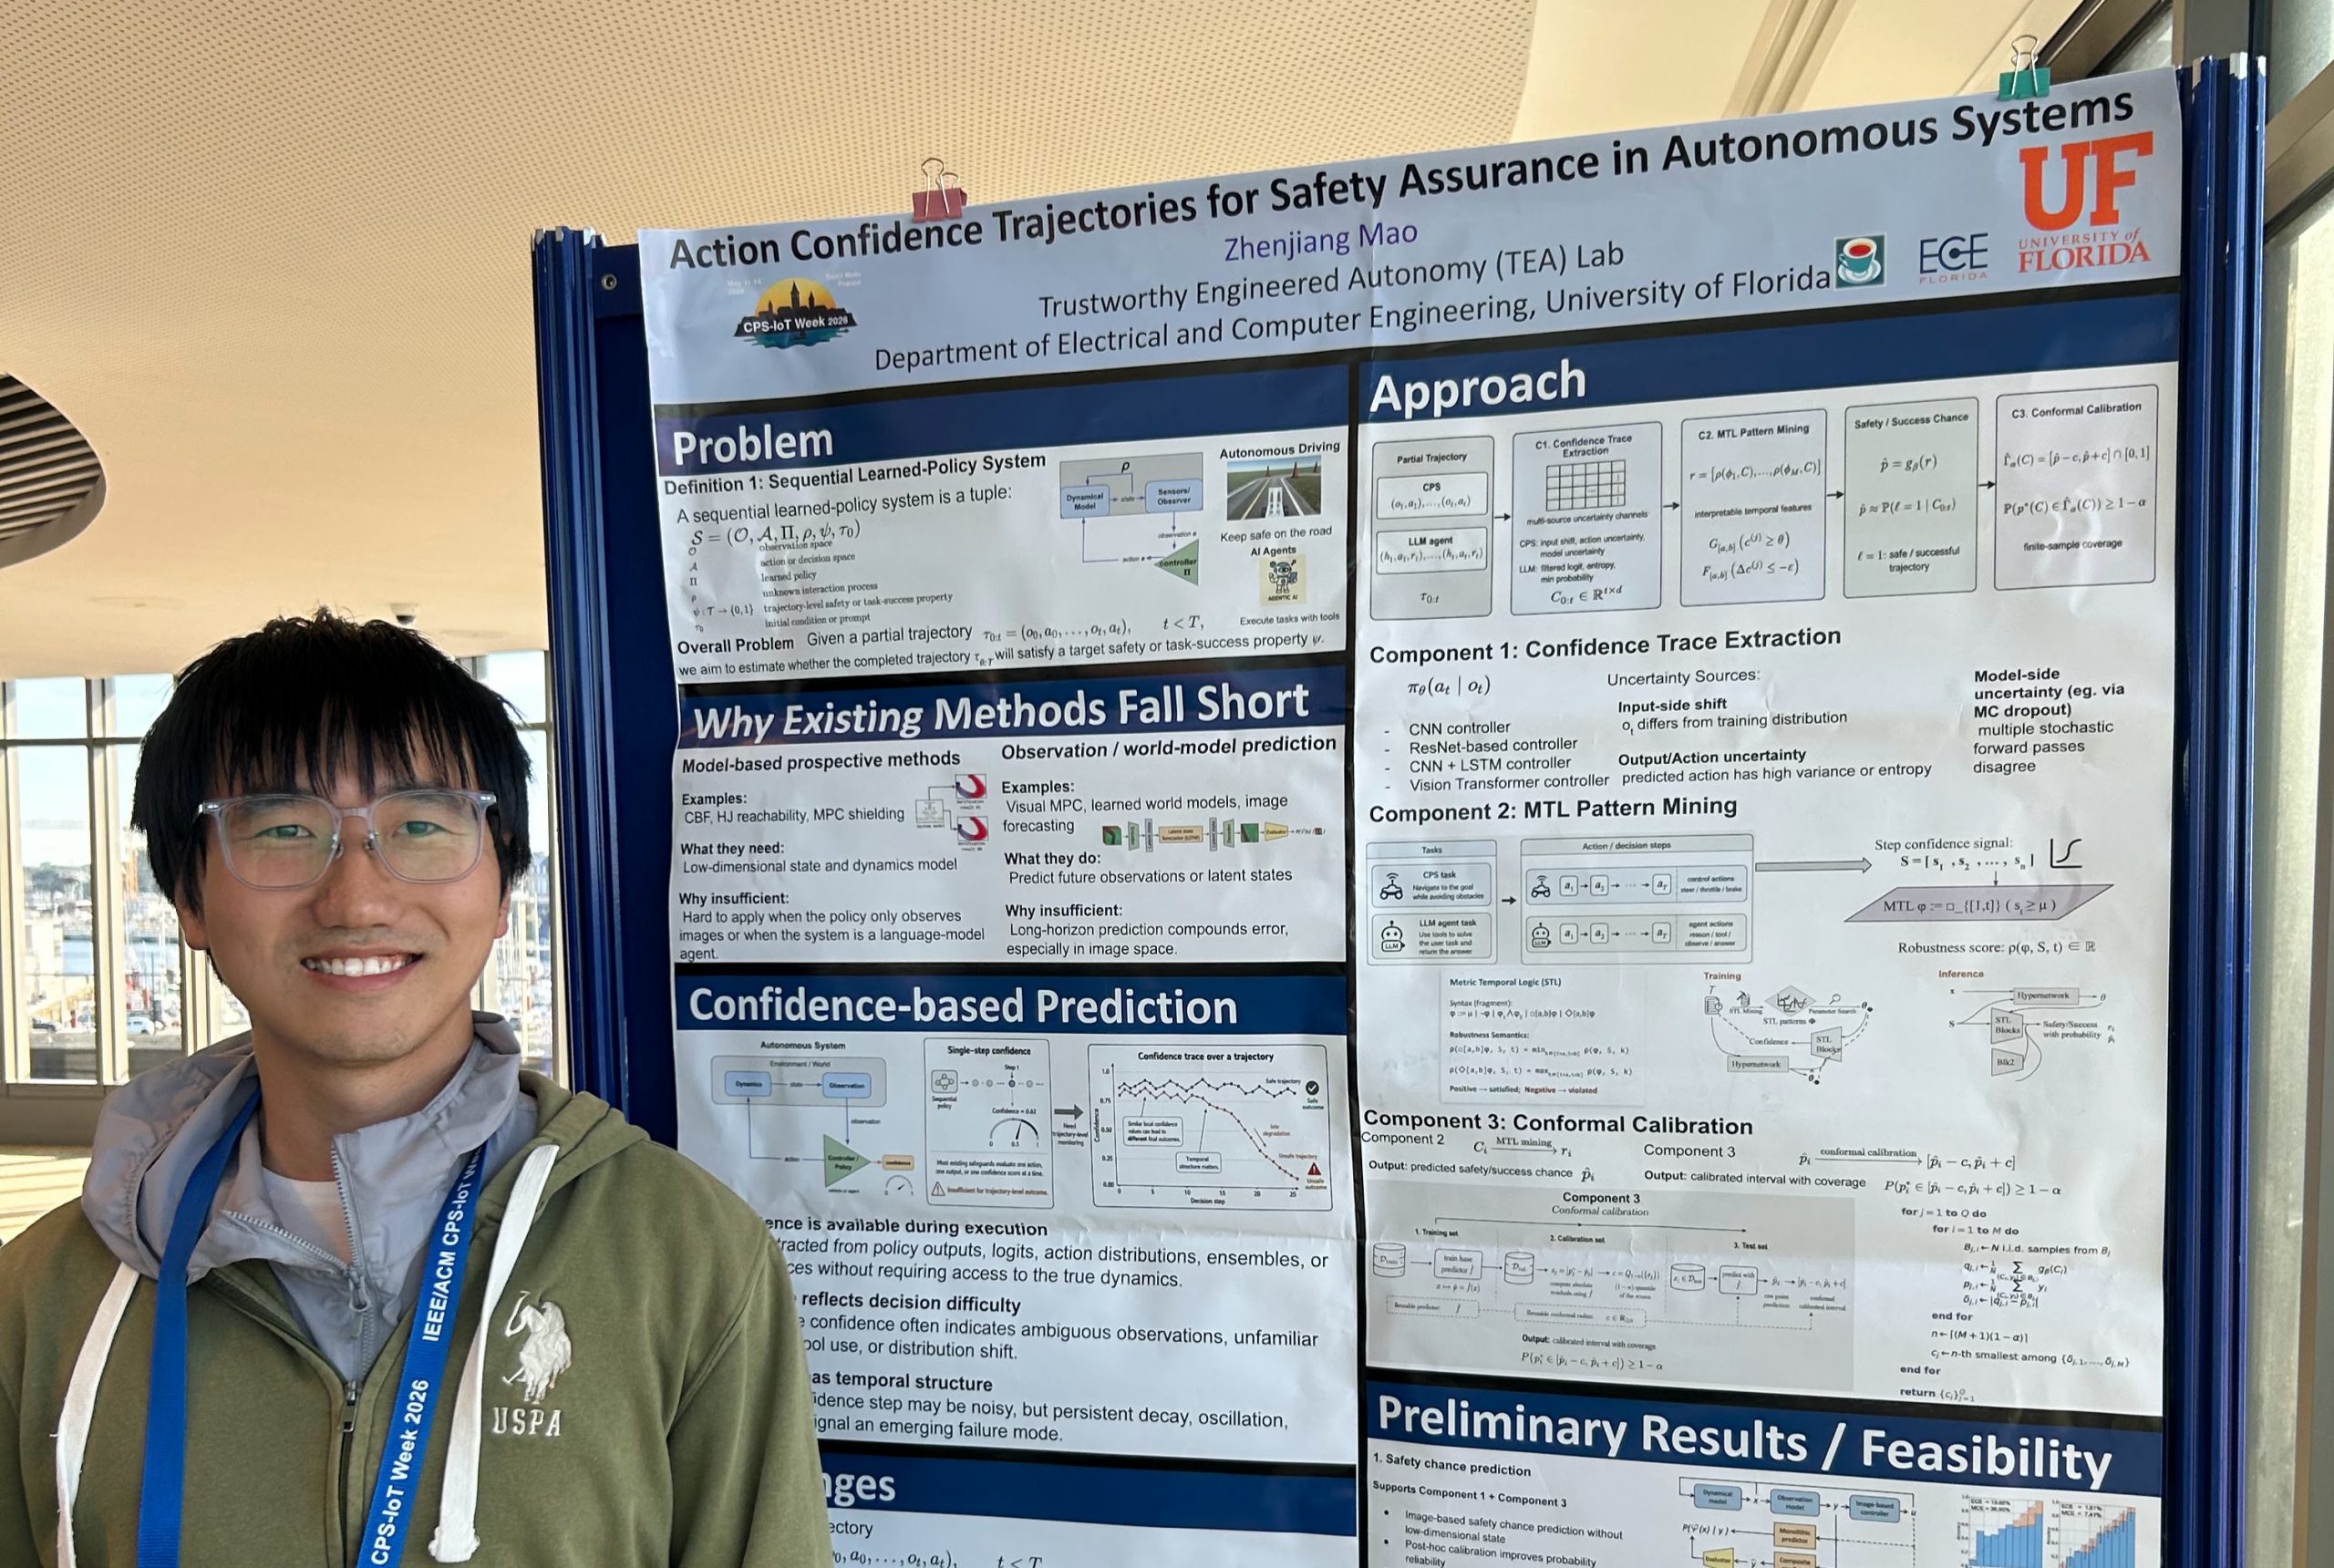
Zhenjiang presents confidences & world models at CPS Week
—
Zhenjiang Mao travelled all the way to Brittany in France to present his recent contributions at the CPS-IoT Week 2026. First, Zhenjiang showcased his proposed PhD work on “Action Confidence Trajectories for Safety Assurance in Autonomous Systems” at the CPS-IoT Week PhD Forum. He gave a short pitch and then presented a poster, which was…
-

Posters at Undergraduate Spring Symposium 2026
—
Congratulations to Trevor and Chris (and Vignesh) on their presentations of undergraduate-led research projects! Featured above: Chris Oeltjen and Vignesh Saravanan with their defensive maneuvering work. Featured below: Trevor Turnquist with his calibrated filtering work.
-

Ivan presents LLM confidence calibration at Shonan
—
Ivan had the honor of attending an invitation-only visionary workshop #235 on LLM-guided assurance and synthesis for CPS in Shonan, Japan. He presented the lab’s work on calibrating chain-of-thought confidence by discovering temporal patterns with Signal Temporal Logic. Materials: Some of the prominent debates at the workshop included:
-
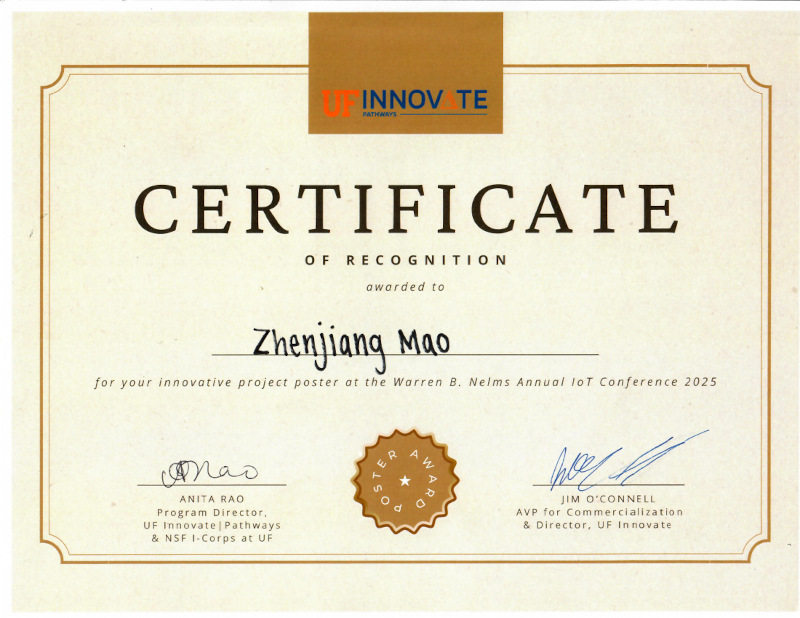
STL CoT confidence = most innovative poster
—
Zhenjiang and Ani presented a poster with their work on chain-of-thought confidence with signal temporal logic at the Annual Nelms IoT Conference. The core idea of this research is to find patterns in LLM confidence that tend to correlate with correct and incorrect answers. Then, these patterns can be used to determine the confidence, i.e.,…
-
Ivan does publicity for a neuro-symbolic conference
—
Ivan Ruchkin is serving as the publicity chair of the 3rd International Conference on Neuro-Symbolic Systems (NeuS) 2026. Looking forward to your submissions!
-
Jordan presents V&V for vision-based systems at ATVA
—
Jordan Peper went all the way to Bengaluru, India, to present our work (in collaboration with UIUC) on unified verification and validation of vision-based autonomy at the International Symposium on Automated Technology for Verification and Analysis (ATVA). Allegedly, this is a hot problem, but the abstraction is quite complex. That’s what it takes — for…
-
IROS showcase: world models, image repair, data cleaning
—
Ivan went all the way to Hangzhou, China, to present several research works on world models, image repair, and data cleaning. Here are the paper citations on which these presentations were based: