Category: Talk
-
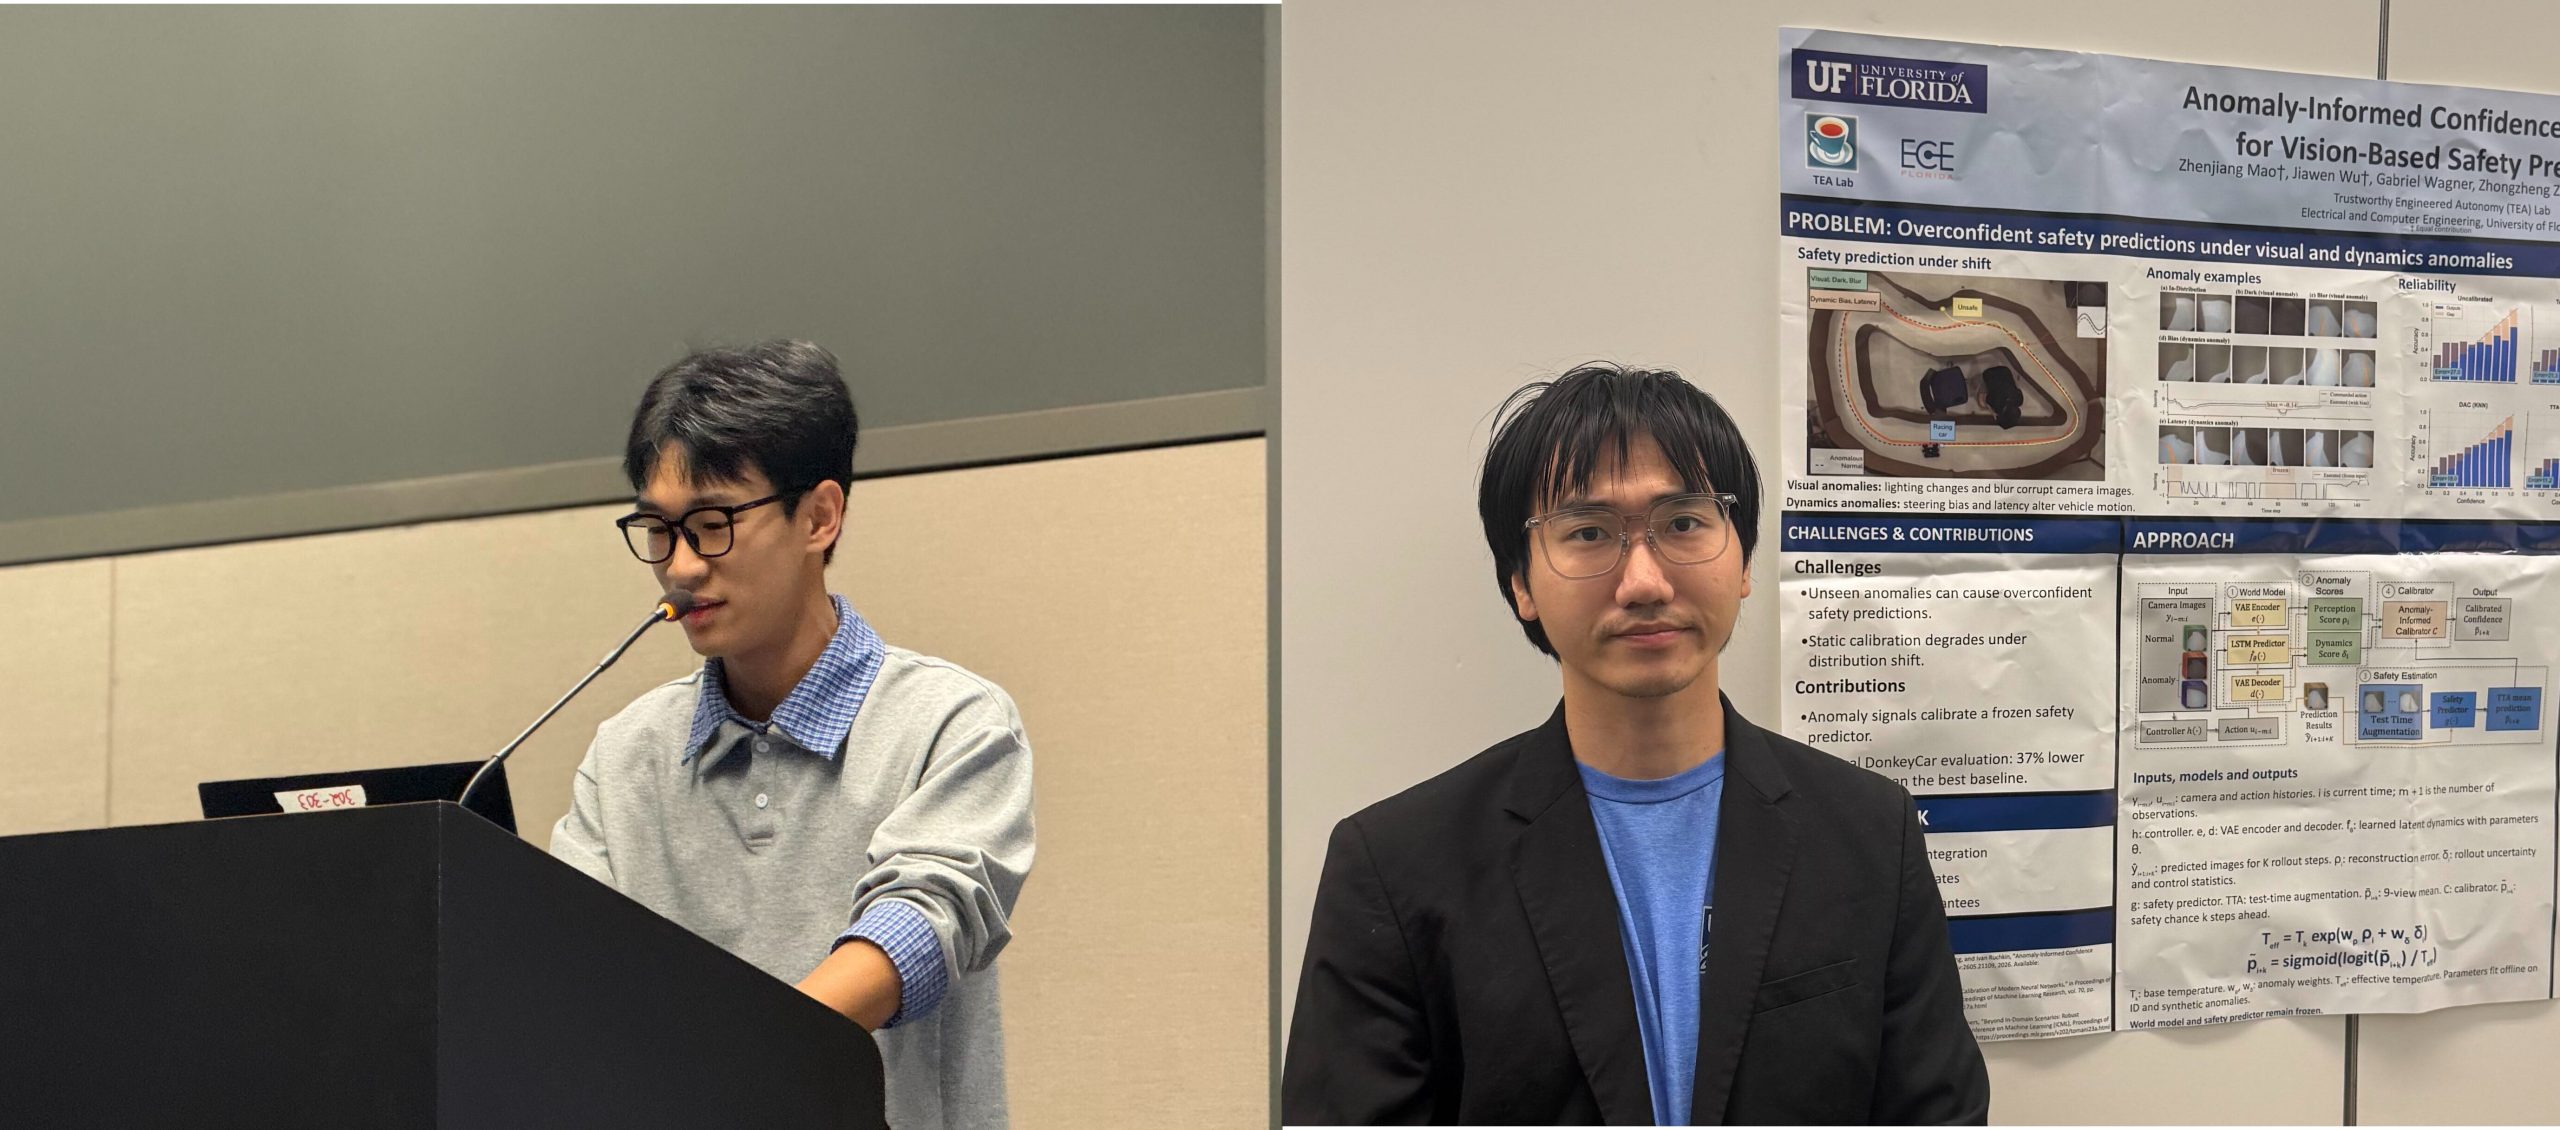
Yuang and Zhenjiang present anomaly research @ IROS
—
Yuang Geng and Zhenjiang Mao went to the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS) in Pittsburgh, PA, to present our lab’s work on mitigating anomalies in imitation learning and trajectory prediction. They went to represent UF as part of a bigger Gator robotics crowd. Presented papers:
-
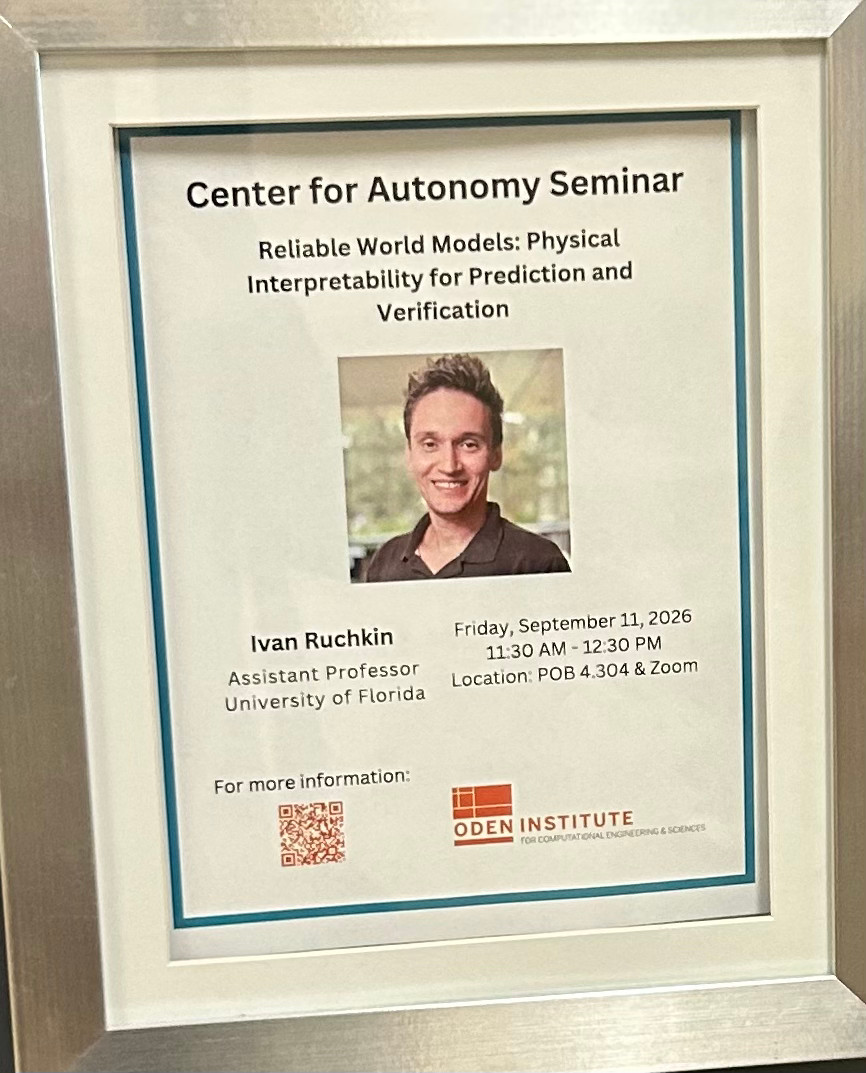
Ivan talks about world models at UT Austin
Ivan visited Ufuk Topcu, the Center for Autonomy, and the Oden Institute at UT Austin with a talk about physically interpretable world models. The discussions included whether anyone has mounted a camera on an inverted pendulum and whether robotics is all about “getting it to work”. The following papers were featured in the talk:
-
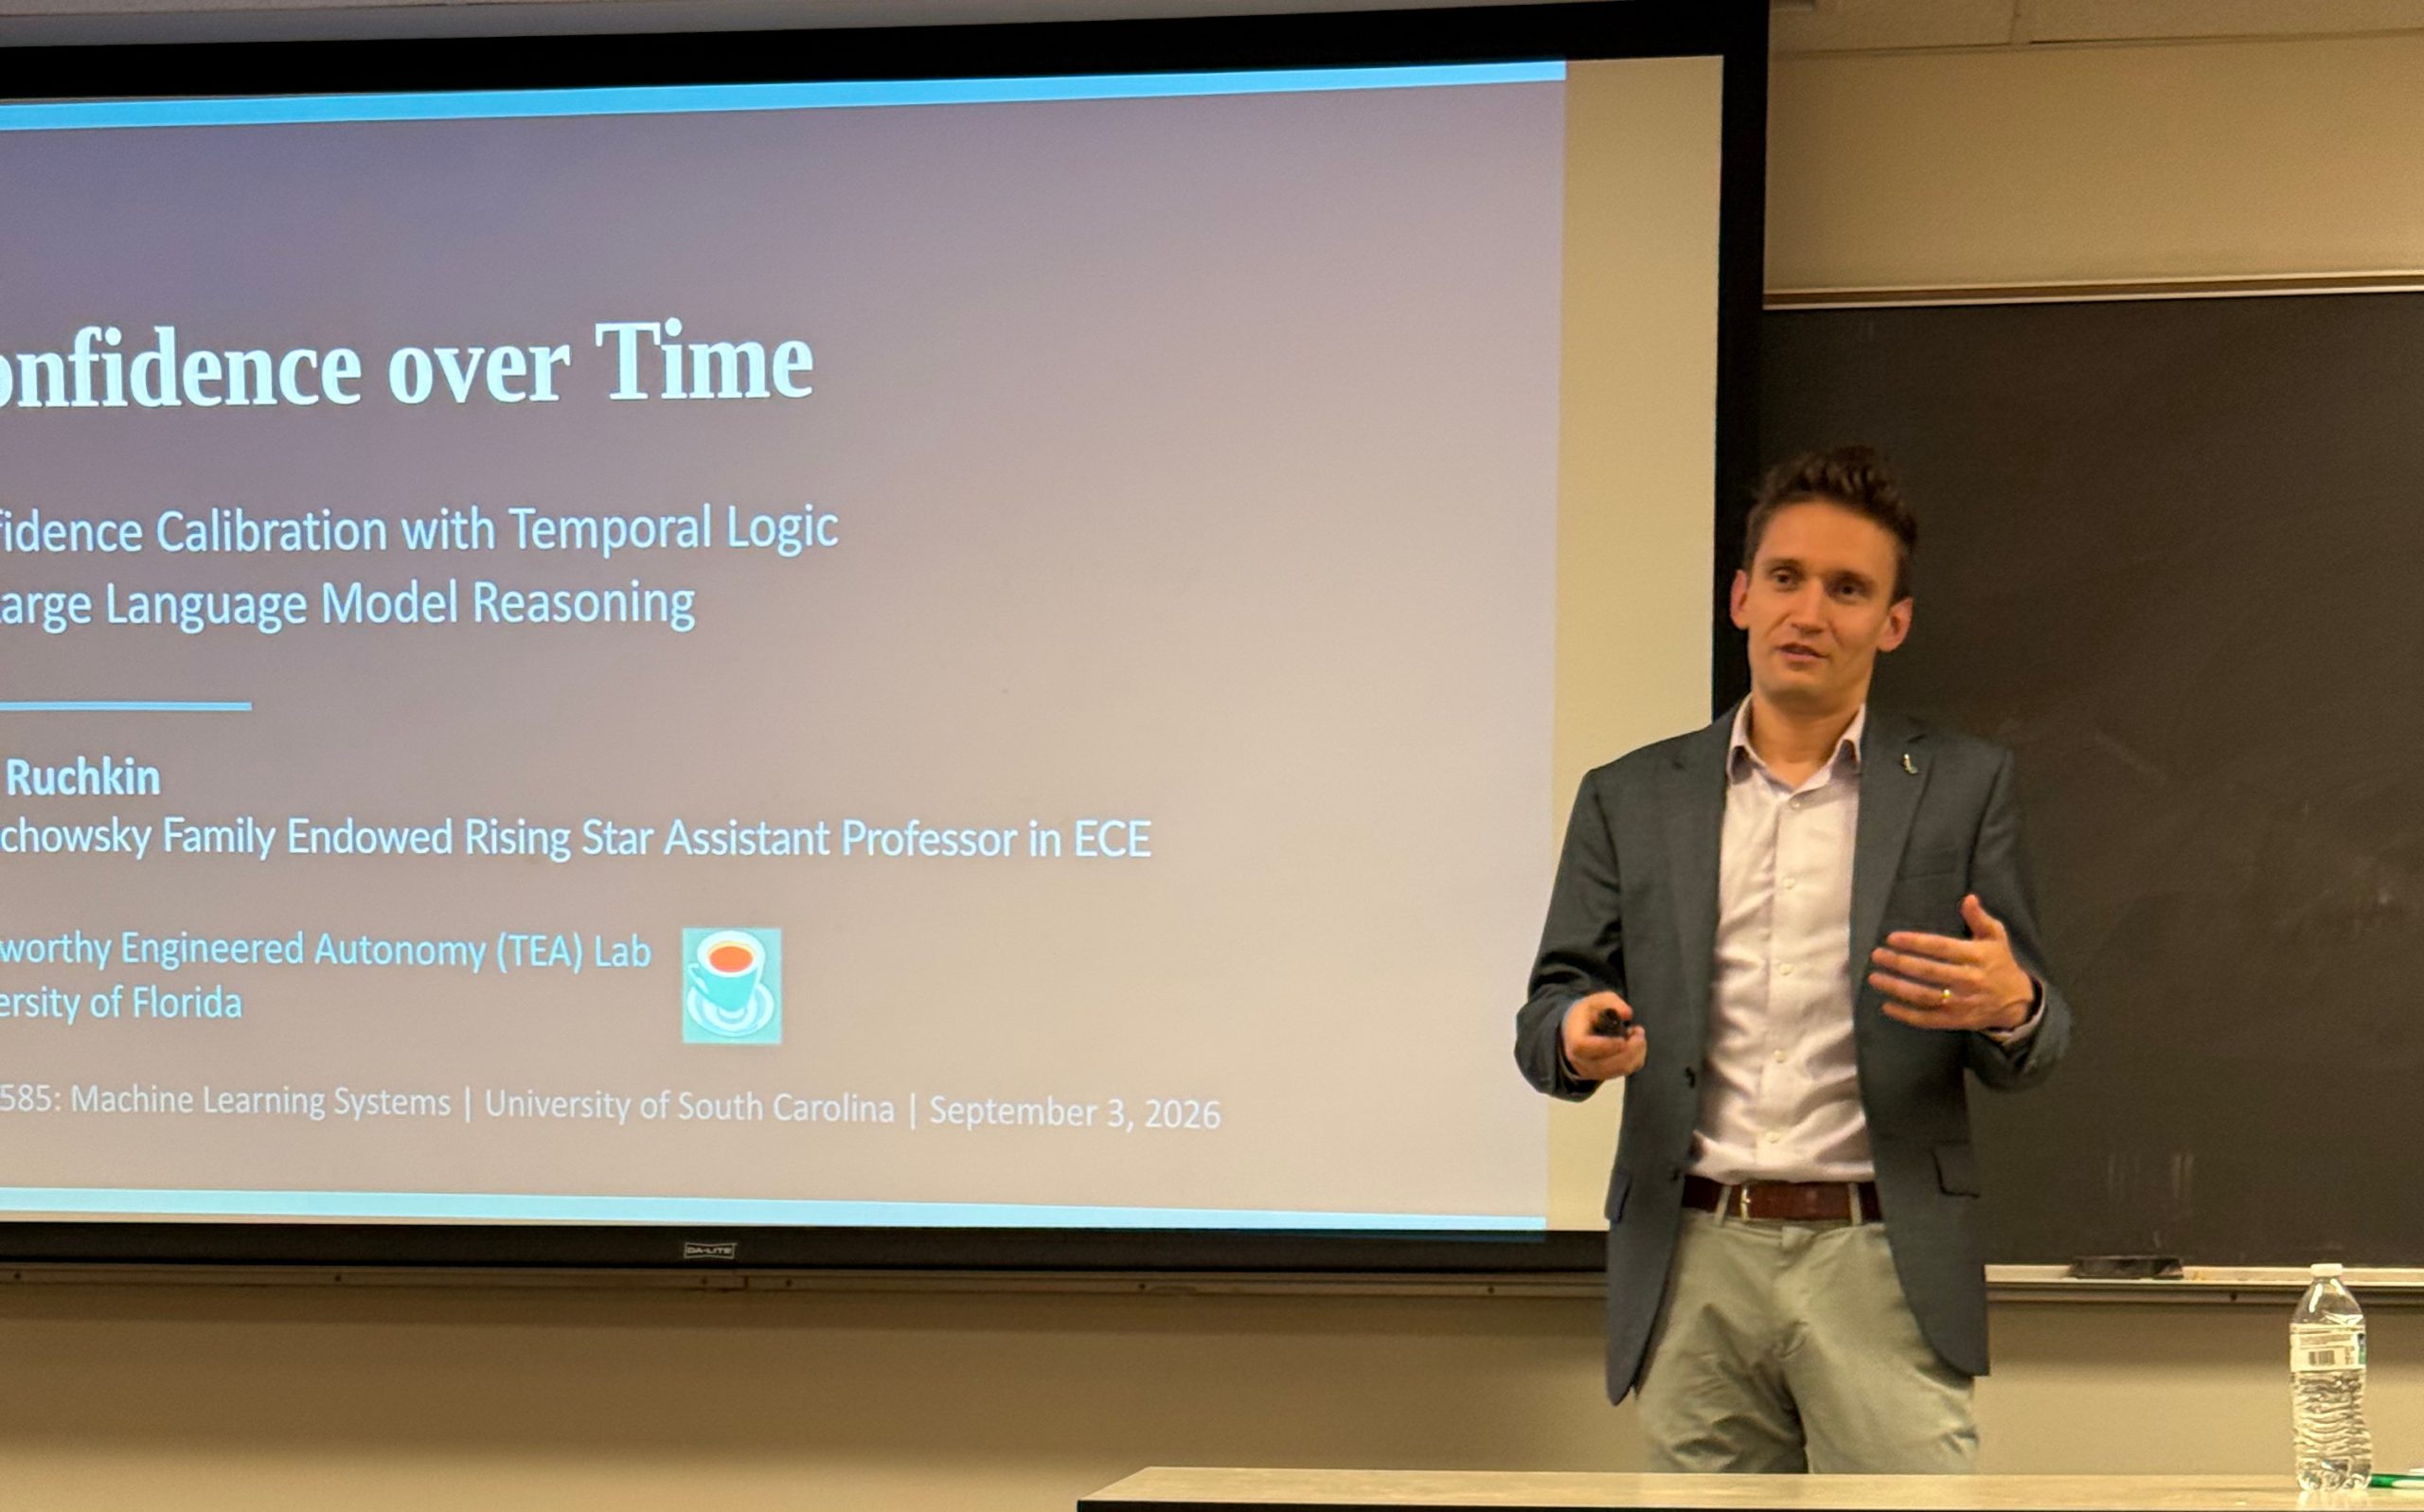
Ivan visits South Carolina with confidence and robustness
Ivan visited Pooyan Jamshidi at the University of South Carolina. The agenda included conversations with like-minded researchers and tours of impressive mechanical, industrial, and electrical facilities. Thanks to UF and the SEC for supporting this academic exchange! In addition, Ivan gave two talks about the recent research on confidence and robustness:
-
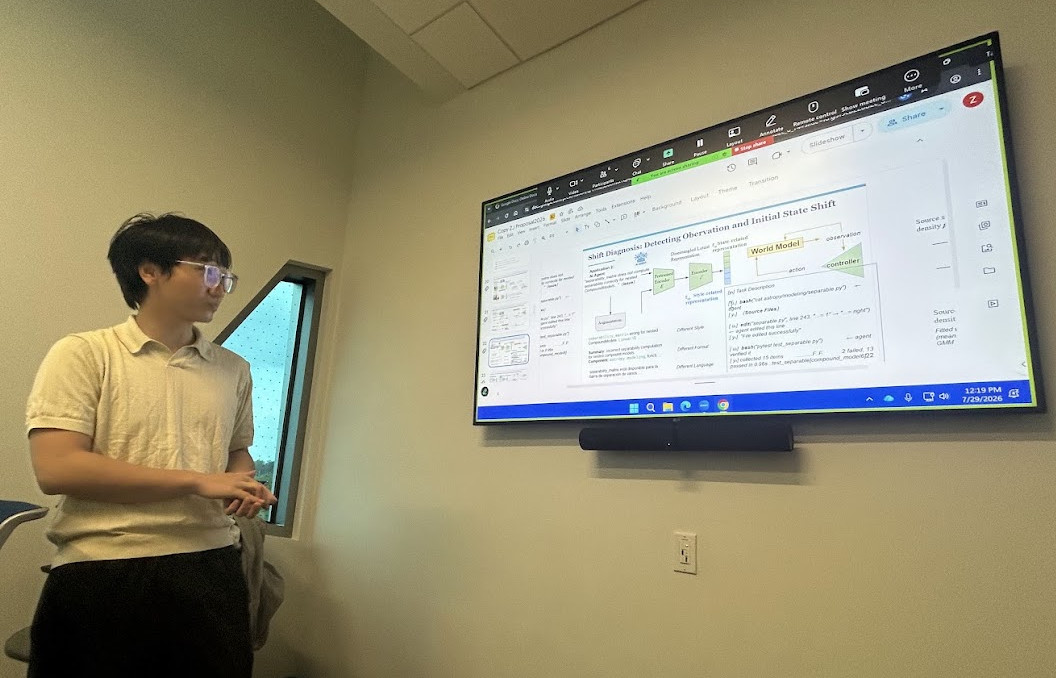
Zhenjiang defends his PhD thesis proposal
The proposed thesis, “Chance Prediction under Distribution Shift: Diagnosis, Calibration, and Guarantees for Visual Autonomy and Language Agents”, outlines a vision for detecting, adapting, and calibrating confidence under 4 types of shifts: observation, dynamics, initial state, and controller. If you are interested in the broader perspective on Zhenjiang’s recent work, check out this article by…
-
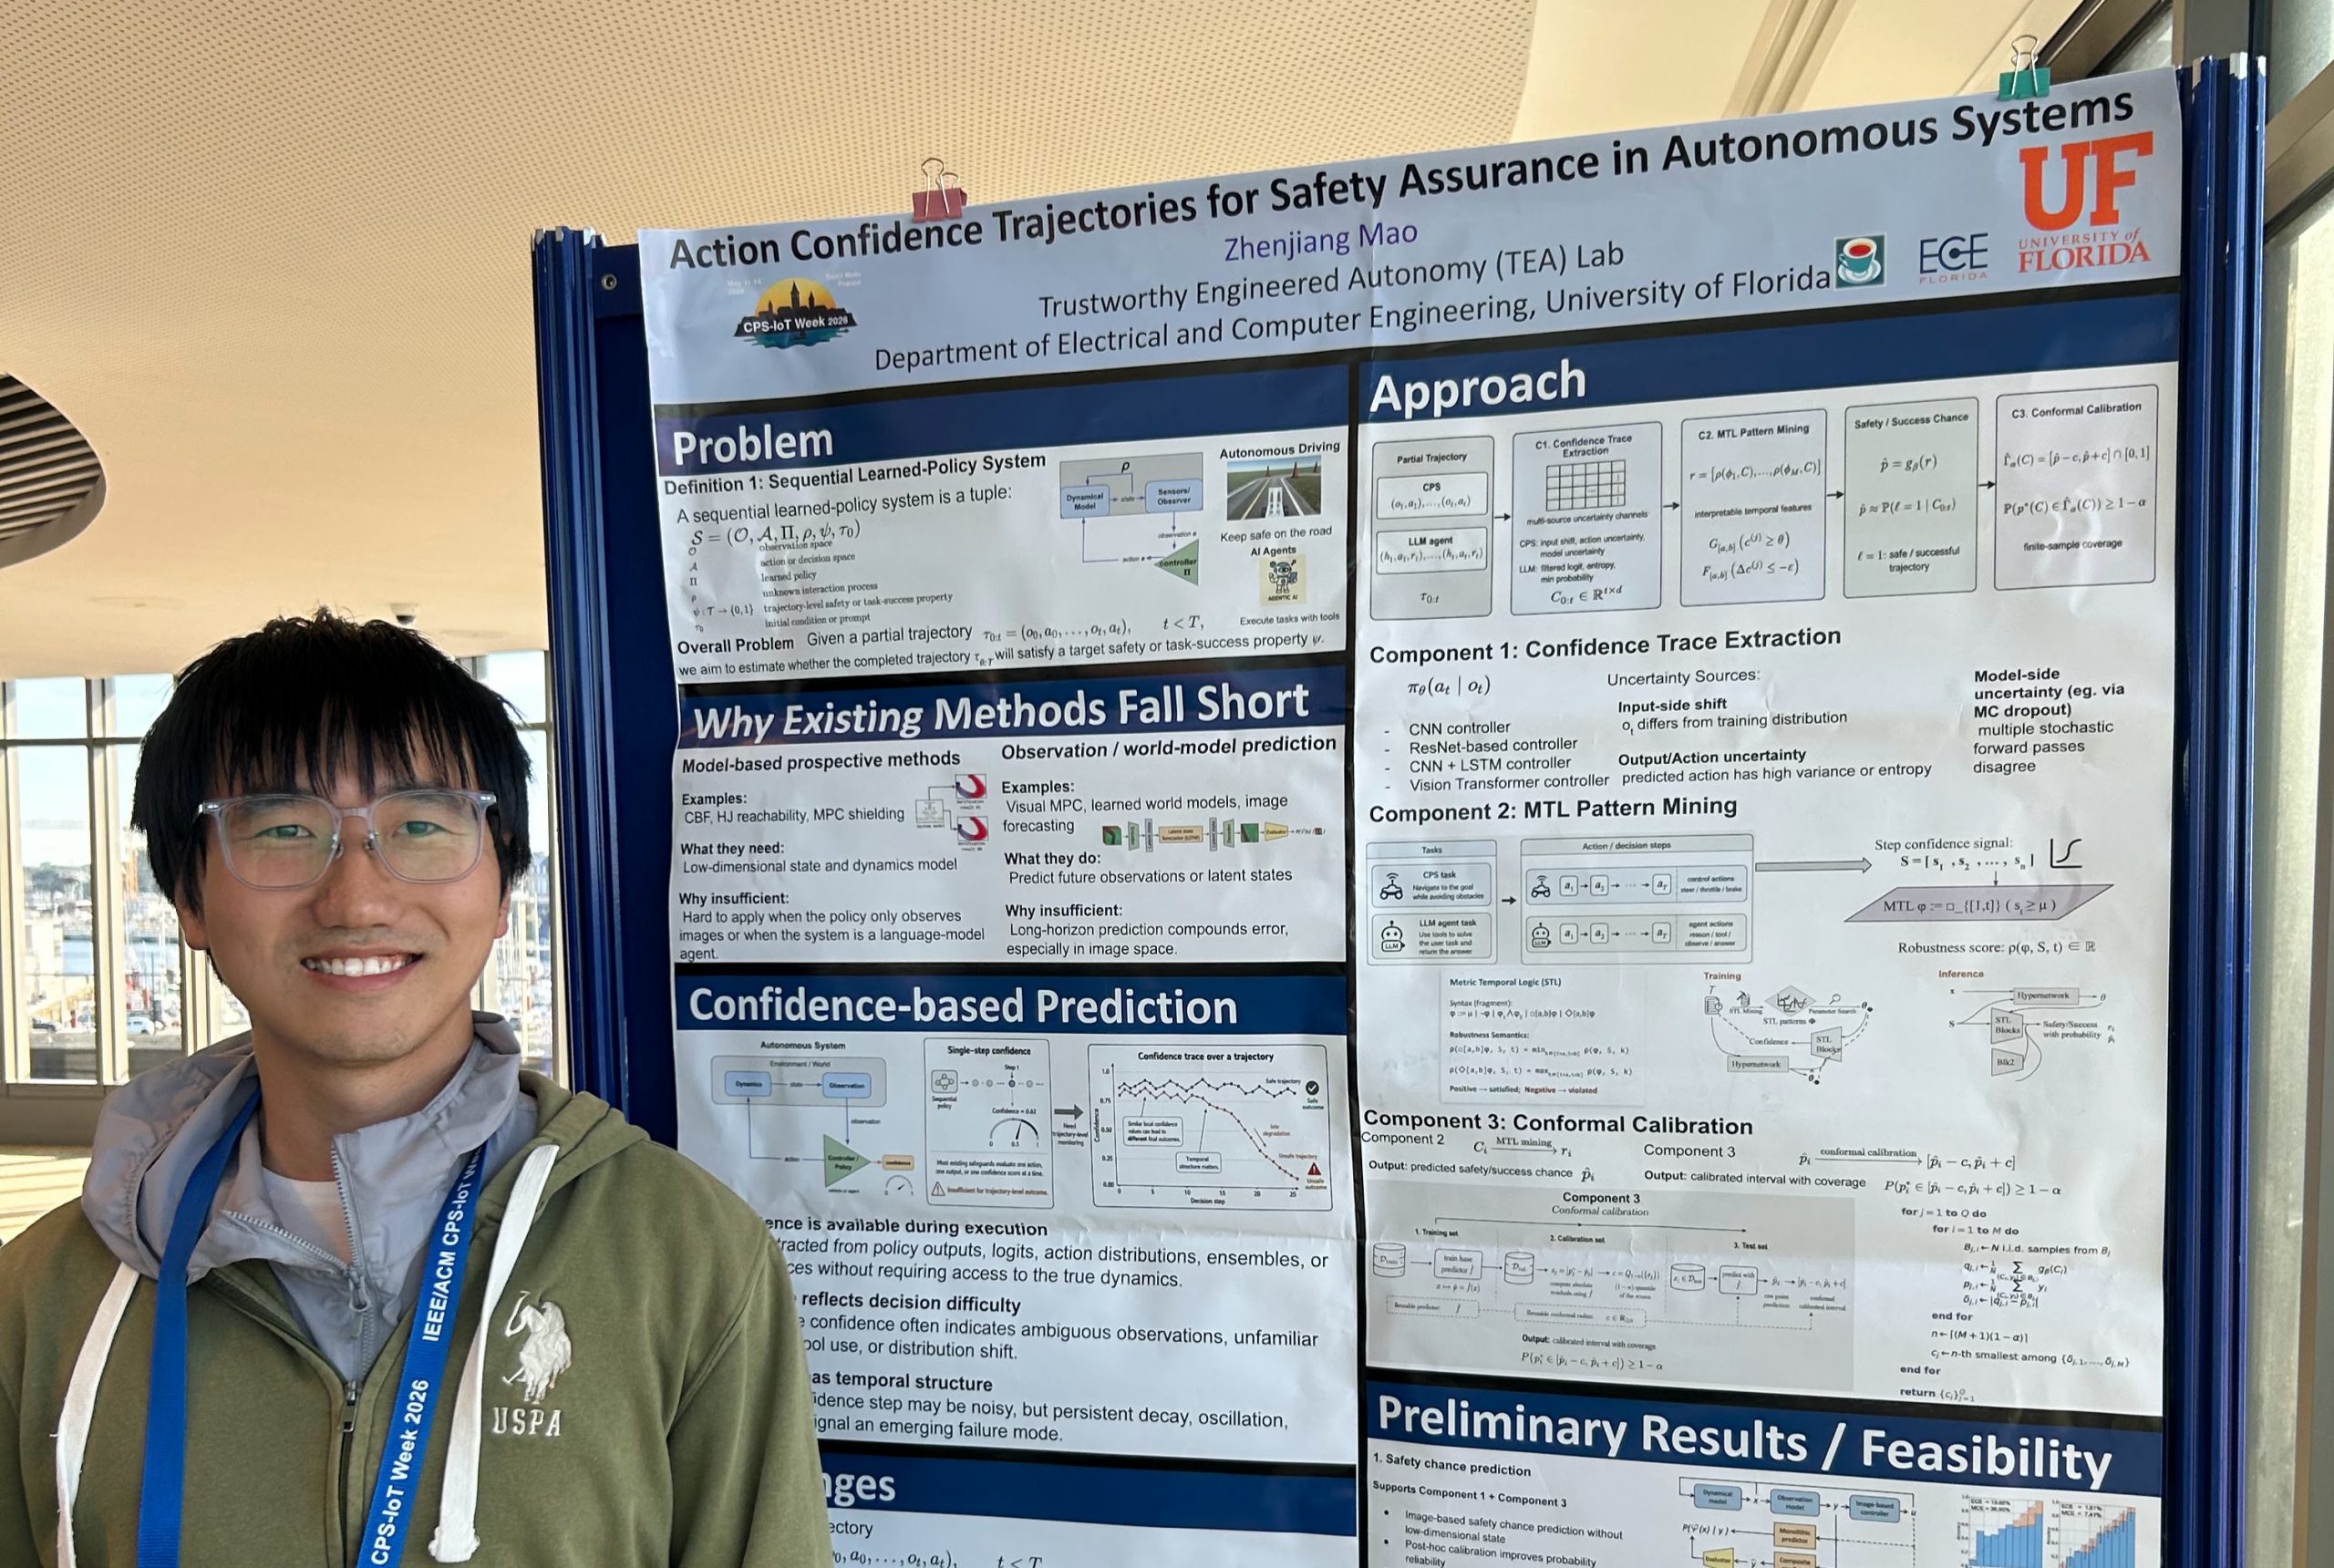
Zhenjiang presents confidences & world models at CPS Week
—
Zhenjiang Mao travelled all the way to Brittany in France to present his recent contributions at the CPS-IoT Week 2026. First, Zhenjiang showcased his proposed PhD work on “Action Confidence Trajectories for Safety Assurance in Autonomous Systems” at the CPS-IoT Week PhD Forum. He gave a short pitch and then presented a poster, which was…
-

Ivan presents LLM confidence calibration at Shonan
—
Ivan had the honor of attending an invitation-only visionary workshop #235 on LLM-guided assurance and synthesis for CPS in Shonan, Japan. He presented the lab’s work on calibrating chain-of-thought confidence by discovering temporal patterns with Signal Temporal Logic. Materials: Some of the prominent debates at the workshop included:
-
Jordan presents V&V for vision-based systems at ATVA
—
Jordan Peper went all the way to Bengaluru, India, to present our work (in collaboration with UIUC) on unified verification and validation of vision-based autonomy at the International Symposium on Automated Technology for Verification and Analysis (ATVA). Allegedly, this is a hot problem, but the abstraction is quite complex. That’s what it takes — for…
-
IROS showcase: world models, image repair, data cleaning
—
Ivan went all the way to Hangzhou, China, to present several research works on world models, image repair, and data cleaning. Here are the paper citations on which these presentations were based:
-
Ivan presents conservative perception abstractions at Allerton
—
Ivan talked about conservative abstractions of perception-driven systems at the University of Illinois Urbana-Champaign in the Allerton Conference. The rumor is that these abstractions are too conservative. Citation:
-
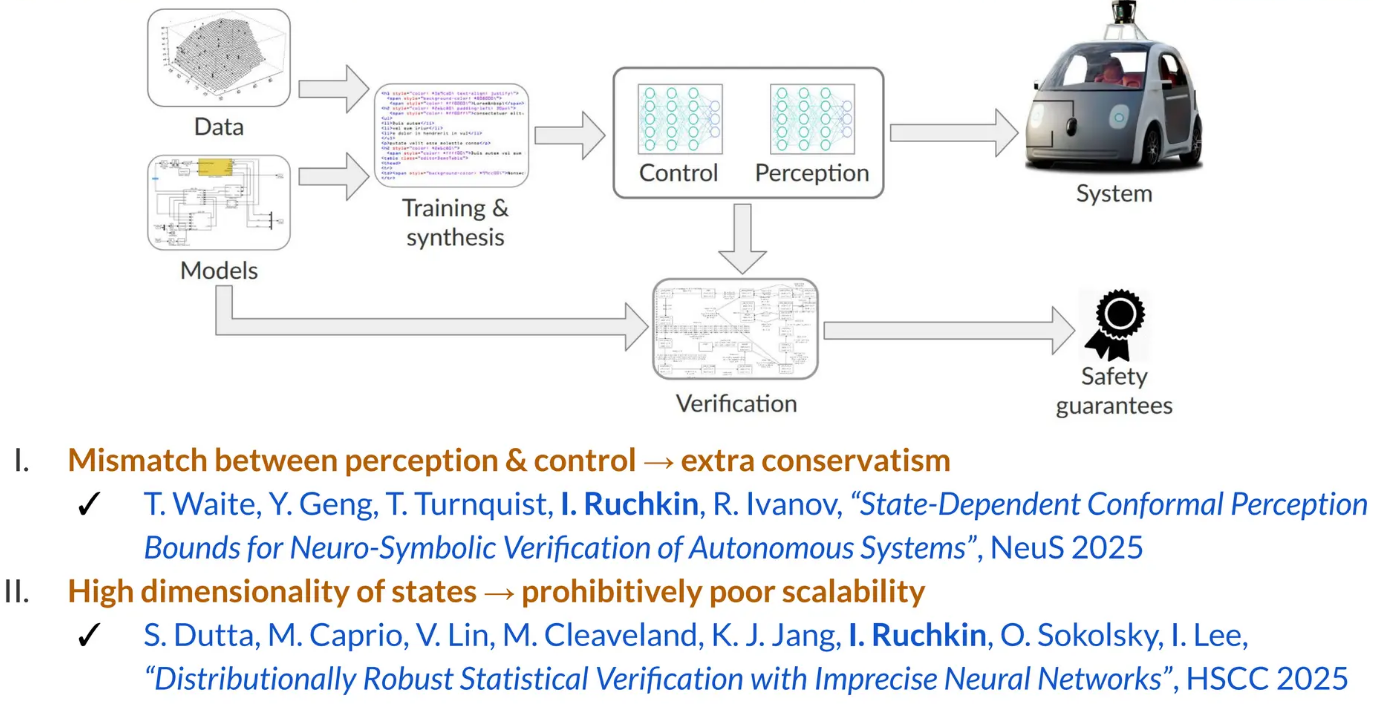
Ivan talks about high-dimensional verification at USC
The talk included methods for dealing with the high dimensionality of perception and state space. Setting a duration record for Ivan’s research talks, it lasted for 90 minutes (thanks to many insightful questions!).