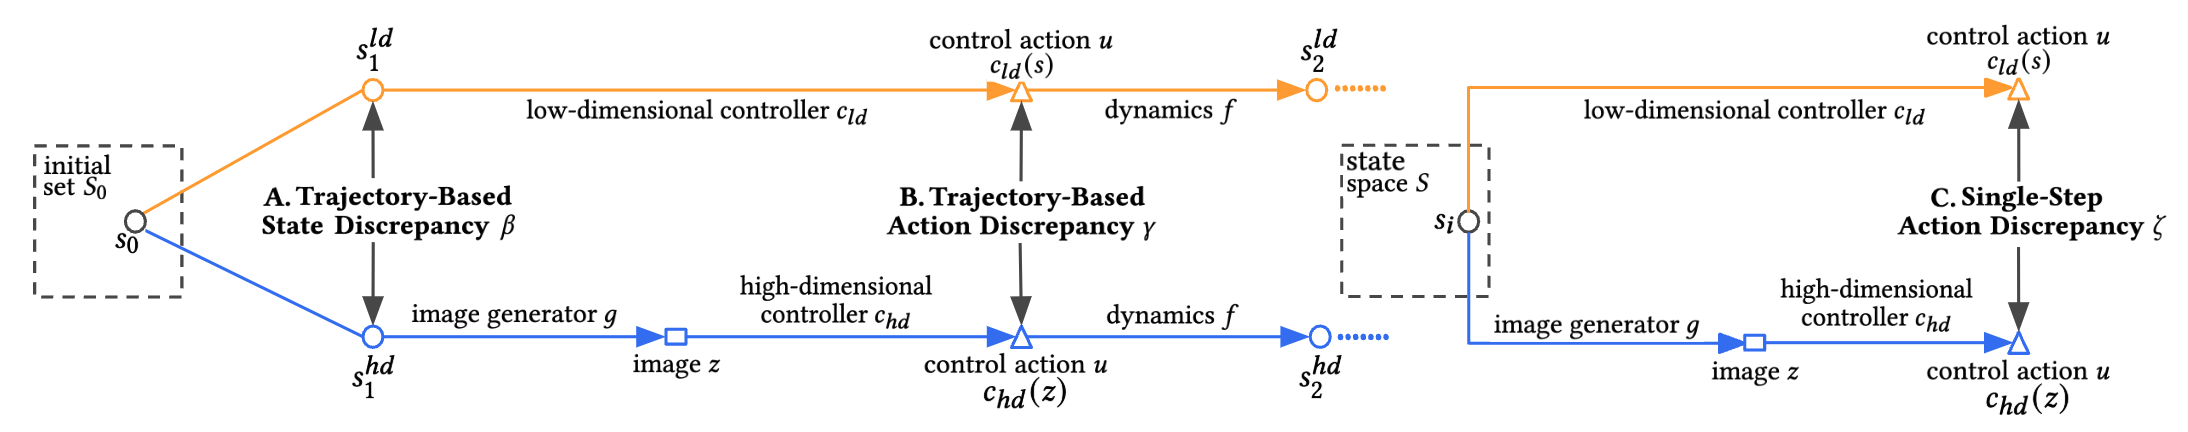
After some waiting, our paper on reachability verification for vision-based control has been published in TCPS. This is an extension of our FM’24 paper on approximating end-to-end vision-action controllers by distillation to several state-based neural controllers. We introduce three quantities to upper-bound the approximation quality: trajectory-based state discrepancy, trajectory-based action discrepancy, and single-step action discrepancy. The latter ends up more precise but pays the price of statistical confidence.
Citation:
- Yuang Geng, Sukanth Sundaran, Chao Huang, Steven Drager, Ivan Ruchkin.
Neural Approximation of Vision-Controlled Systems for Reachability Analysis [ACM] [Demo (w/ subs)] [Demo (w/o subs)].
In the ACM Transactions on Cyber-Physical Systems (TCPS), 2026.
Thanks to our collaborators at Southampton and AFRL!